

5-day
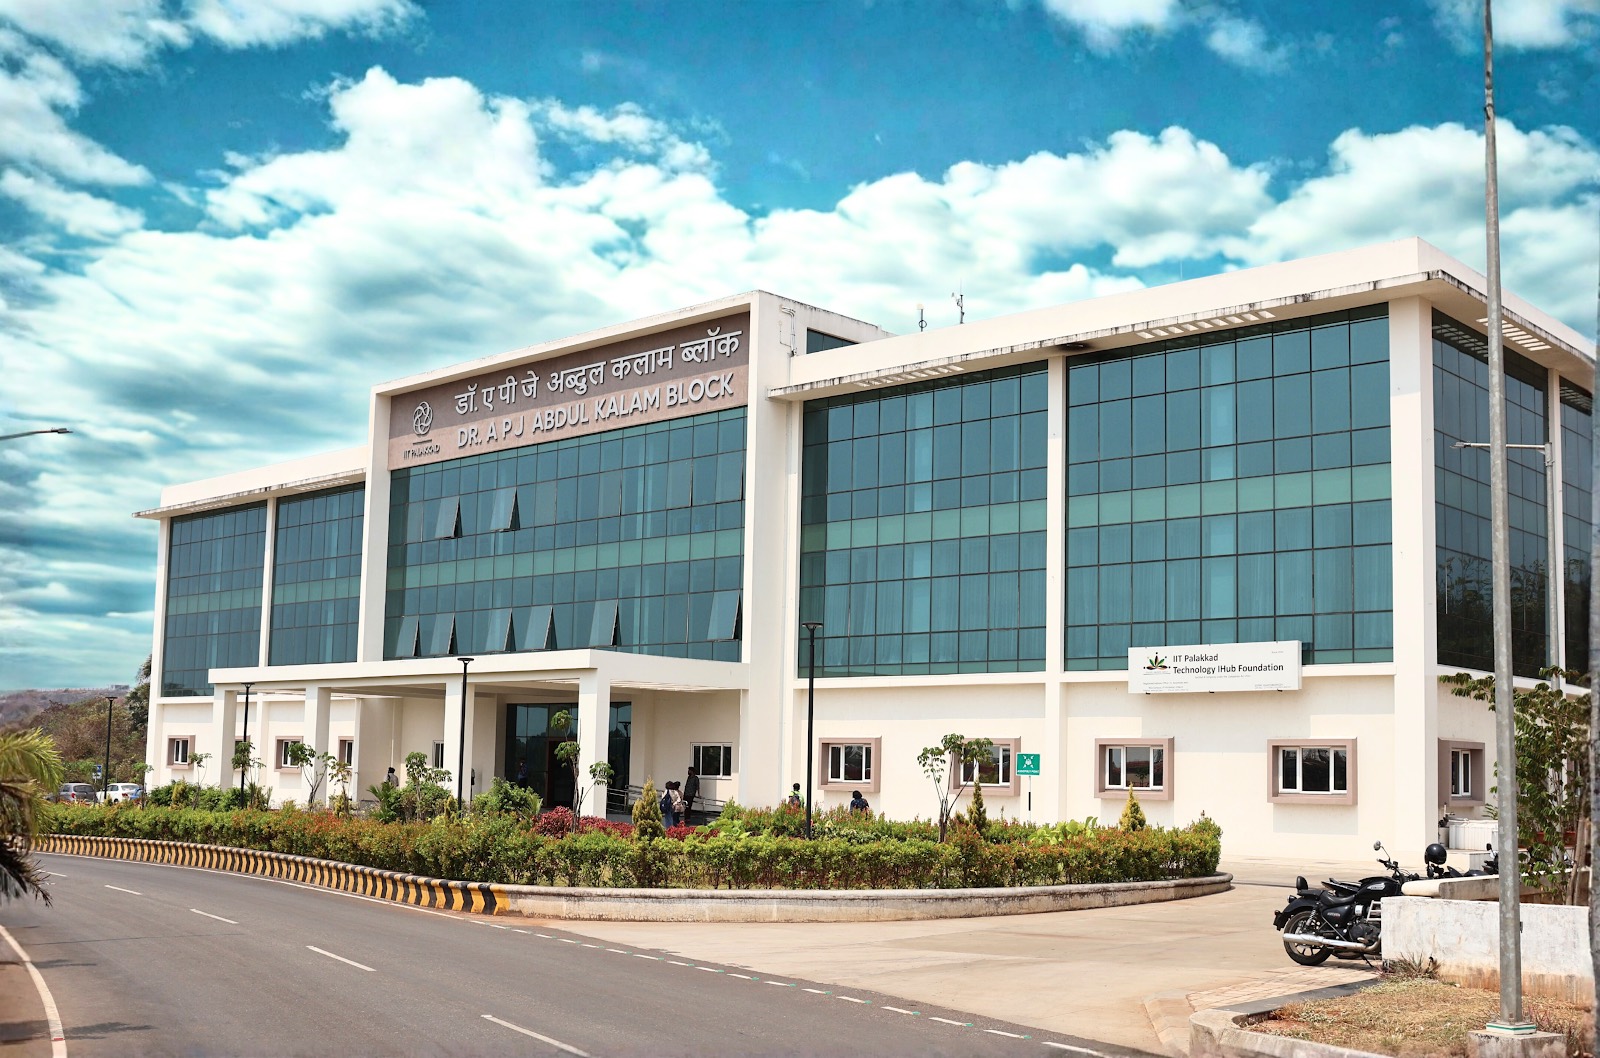
Optional lab at TIH, IIT Palakkad
30
Seats a batch
What you'll build
-
A perception stack that runs on a real robot — detection, tracking and depth taken out of the notebook and onto hardware during the optional five-day lab at TIH, IIT Palakkad.
-
A smart-city traffic monitoring system — vision under real conditions: occlusion, weather, changing light and a camera that never sits still.
-
An end-to-end ML pipeline — cleaning, features, training and evaluation built so it can be re-run and trusted, not demoed once.
-
A voice-to-robot command simulation — speech to intent to motion, where a language model has to drive something physical that can actually get it wrong.
How roles evolve with AI
- Computer Vision Engineers building the perception layer for machines that have to see and act in the physical world.
- Robotics Researchers working on motion planning, SLAM and learned control at the frontier of autonomy.
- Deep Learning & AI Engineers taking models to the edge — optimised, deployed and monitored on real hardware.